


This article presents an approach to morphing flaperon design. The presented design workflow attempts a simple structural arrangement of trailing edge morphing for applicability in the short term. The purpose of this paper is to test the optimization of the geometry built in for future multidisciplinary flaperon optimization techniques.
To meet the contrary requirements on stiffness and compliance of the morphing structure, the design is performed as a multi-objective optimization problem solved using a genetic algorithm. The objective function for optimization incorporates the failure index, target deflection and actuation force for both upper and lower deflection. To produce the single objective value a weighting is used. The constraints and conditions are used to reduce the resulting dependency on weighting factors selection. The described problem was solved using Matlab scripting, combined with a structural Nastran finite element method solver to determine individual’s properties for evaluation and selection.
The problem formulation and design workflow fulfill the goal. The obtained set of parameters defines the morphing flaperon geometry, that allows achieving the described deflections with the required failure indexes and with minimal actuation force, therefore verifying the morphing mechanism. The design workflow proved feasible and will be further developed.
The presented workflow allows to find the geometry for specified material properties and airfoil shape. Therefore, an engineering approach is offered to assess the combination structurally for the specified deflection range with minimal actuation force. The morphing trailing edge in combination with a laminar airfoil has not been given much attention yet.
Nomenclature
Symbols
- {a}
= Weighting coefficients vector;
- δup
= Resulting deflection angle up for given input parameters;
- δdown
= Resulting deflection angle down for given input parameters;
- E
= Young elastic modulus of isotropic material;
- ex
= Front end of the morphing skin, parameter, ratio of airfoil chord length;
- fx
= Rear end of the morphing skin, parameter, ratio of airfoil chord length;
- f
= Objective value – output of the objective function after weighting;
- γ
= Angle of the guiding rail for the hinge pin, parameter tg(γ);
- kup
= Penalization coefficient based on improper deflection angle up;
- kdown
= Penalization coefficient based on improper deflection angle down;
- ν
= Poisson ratio of isotropic material;
- qc up
= Actuation force required for upper deflection, distributed spanwise;
- qc down
= Actuation force required for lower deflection, distributed spanwise;
- FIup
= Failure index achieved in upper deflection;
- FIdown
= Failure index achieved in lower deflection;
- σa
= Allowable von Misses stress in morphing skin;
- σi
= Von Misses stress in morphing skin i-th element; and
- t
= Thickness of the morphing skin;
Acronyms
- AMC
= Acceptable means of compliance – appendix of CS23;
- CS23
= Certification specification of EASA for normal, utility, aerobatic and commuter aeroplanes;
- CFRP
= Carbon fibre reinforced polymer;
- EASA
= European Union Aviation Safety Agency;
- FEM
= Finite element method;
- GA
= Genetic algorithm; and
- GFRP
= Glass fibre reinforced polymer.
Introduction
Airfoil morphing is the ability to change the cross-sectional profile of an aerodynamic surface, which may substitute traditional control surfaces and high-lift devices that use rotational, translational or combined movement. Many concepts emerged throughout the decades. Barbarino et al. (2011) offered a complex review of the technology and Thill et al. (2008) focused on the morphing skins. Some concepts change the shape of an airfoil along its full chord length like the concepts of Peel et al. (2009) or Previtali and Ermanni (2012). Others only morph a part of an airfoil (Kensche, 1954; Smith and Lock, 1992). The morphing of the smaller part of an airfoil is generally a substitution of the leading or trailing edge devices. The advantage of this approach can be seen in simpler design and keeping the standard wing inner structure which may help to apply the technology in the shorter term. While Moorhouse et al. (2006) suggested that solutions to wing structure other than the box beam configuration must be investigated, this presents a very complex task. Even nowadays a large portion of projects focuses on morphing of the part of an airfoil e.g. leading edge (Vasista et al., 2019) or trailing edge (Klimczyk and Goraj, 2019) while keeping the standard spanwise wing structure.
A frequently revisited concept of this type is the substitution of the trailing edge control surface hinge with a continuous load-bearing upper skin. The skin bends to achieve control surface deflection. This concept can be seen in the work of many authors throughout the years (Kensche, 1954; Thomas and Laude, 1968; Heintz, 1999) and is still developed nowadays (Wu et al., 2017; Cheng et al., 2023). However, the combination of such a concept with the modern laminar airfoil was not given much attention. In the morphing of the modern flapped laminar airfoils and the sailplane design, the leading-edge morphing by Achleitner et al. (2019) and Sturm et al. (2019) is very recognizable.
Morphing concepts, that involve the elastic deformation of the structural parts, present a contrary structural requirement. Stiffness is required to maintain a specified shape and distribute loads, whereas compliance is necessary to reduce the actuation force of the morphing elements. Therefore, such a structural design is always a multidisciplinary problem and leads to a complex optimization problem. This was well described by Campanile (2005). It is desirable to keep the arrangement simplistic, with a low part count to avoid structural weight increase, which might compromise the benefits of morphing.
Design
The proposed morphing flaperon uses the elastic load-bearing upper skin which connects a rigid wing structure with a rigid flaperon as shown in Figure 1. The skin bends for flaperon deflection. The lower surface skin is split. The split is covered using tape, which is a regular and commercially available solution on control surfaces. Future design might involve elongating skin. At the lower surface, an actuation push/pull rod connects to the flaperon. The connection pin is guided in the straight slot/rail which is a part of the wing body. The slot/rail supports the vertical translational forces of the flaperon and distributes them to the main wing body.
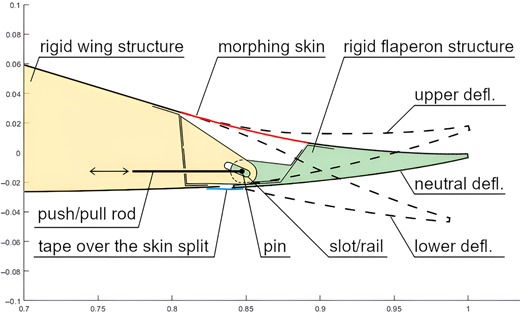
Morphing flaperon structural arrangement on the airfoil trailing edge, unit lengths
Source: Authors’ own work
Morphing flaperon structural arrangement on the airfoil trailing edge, unit lengths
Source: Authors’ own work
The morphing upper skin is subjected to bending stress and strain during the deflections. Depending on the orientation of the deflection, it is also subjected to tensional load (for upper deflection) and compressive load (for lower deflection). These loads are formed as a reaction to the actuation force. This cannot be avoided as the force couple is needed to create a flaperon deflection moment. In addition, the aerodynamic hinge moment adds to these forces and moments. It is assumed that the dominant aerodynamic force acts against the flaperon deflection and therefore increases the actuation force on the push/pull rod.
Considering the properties of the morphing skin, the actuation force required for flaperon deflection depends on the bending stiffness of the morphing skin. For the selected material with a given elastic modulus, only the reduction of the morphing skin thickness can be used to reduce the actuation force. Lowering the skin thickness also lowers the bending stress at given deformation but it increases the axial stress, which is limited by the required failure index. Therefore, an optimal skin thickness can be found.
Considering the geometry of the morphing flaperon, the morphing skin length and chordwise location are also subject to selection. The longer morphing skin allows higher flaperon deflections with lower strain as this can be distributed better. On the other hand, longer morphing skin carries higher aerodynamic loads and is susceptible to buckling issues. The slot incline (positive or negative) can adjust the morphing skin loading in the motion. It can also influence the actuation force. As can be seen, the selection of geometrical parameters is an optimization problem.
Method
As was described above, the shape definition of the airfoil offers several variables to optimize the flaperon built-in geometrically. The objective of the optimization is to receive the parameters for geometrical configuration that will enable reaching the selected flaperon deflection with a suitable failure index with minimal actuation force for both upper and lower deflection.
For the preliminary design, the following simplification and assumptions are used. The only deforming part is the morphing skin, all other structural parts are considered rigid bodies. Aerodynamic verification of the final morphed shape is not present in this preliminary design to reduce its complexity. Aerodynamic loads are simplified and estimated using the CS-23 acceptable means of compliance (AMC) procedure [European Union Aviation Safety Agency (EASA), 2015]. The optimization workflow is tested on the modified kl-012-132f laminar airfoil from the optimization by Kubrynski (2012). The airfoil was chosen to represent the flapped laminar airfoils. Its small relative thickness makes it a challenging boundary condition as the internal space limits the available force couple arms. The presented workflow can be generally applied to any other airfoil.
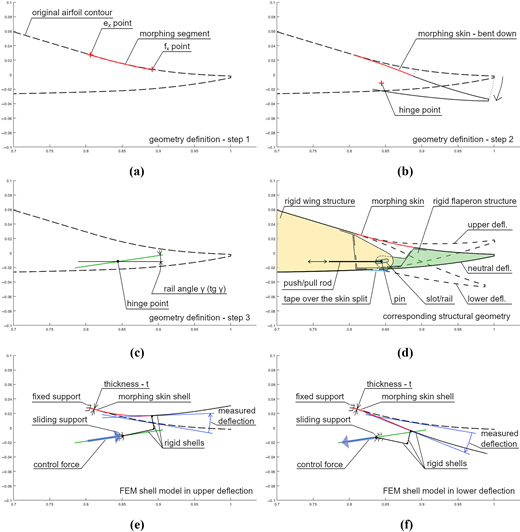
The sizing of the rigid parts and the elastic part of the airfoil is defined in a parametric way. It follows the design features for the morphing described above. The steps are illustrated in Figure 2:
Parametric geometry definition and FEM shell models in deflections
Source: Authors’ own work
Parametric geometry definition and FEM shell models in deflections
Source: Authors’ own work
In Step 1, the 2 main geometrical parameters are set, as shown in Figure 2(a). Those are chord length ratios to split the rigid wing part from the morphing skin (ex point) and the morphing skin from the rigid flaperon (fx point). Where fx > ex. (Practical equivalent to length and chordwise location.)
In Step 2, the morphing segment is geometrically bent down by the selected deflection angle with an assumed circular arc shape in between the rigid wing and rigid flaperon structure. Such a shape of constant curvature in the morphed state equalizes the bending moment along the skin. The resulting shape calculated in structural solver need not be exactly arc shaped but the objective function will favor such geometries, where this shape is approached, because of the better strain distribution and therefore lower stresses.
The rigid flaperon part is joined tangentially with the morphing segment and follows it in the bending motion. In such motion, the lower curve of the rigid flaperon intersects with the original lower curve of the airfoil. Above that intersection, the hinge point is located, where the push/pull control rod connects to the rigid flaperon. The vertical distance is given by the minimum possible distance from the rigid flaperon lower skin based on the structure and need not be optimized. For the preliminary design, this is assumed to be 0.5% of the chord length. See Figure 2(b):
In Step 3, the rail angle parameter (tan γ) is selected. Setting the rail angle allows for modification of the morphing skin curve during the flaperon movement and redistributes the forces. See Figure 2(c).
The corresponding structural geometry of the design is in the Figure 2(d). The finite element method (FEM) model comprises the isotropic morphing skin shell and the 3 rigid shells that substitute the rigid flaperon structure. The thickness of the morp hing shell (t) is the 4th optimization parameter. The fixed support is used where the morphing skin is connected to the rigid wing structure. The sliding support models the rail connection of the flaperon and the wing. The actuation force is applied at this shell edge in the direction of the free movement. The orientation of the actuation force is selected to produce the upper or the lower deflection. In Figure 2(e), the pushing actuation force produces the upper deflection. In Figure 2(f), the opposite orientation and deflection are shown. In both cases, the deflection of the flaperon is measured on the rigid part of the flaperon. The FEM model applies an actuation force, to reach the required deflection from the original airfoil contour.
Optimization problem
The optimization objective is to achieve both the upper and lower deflection with appropriate failure index, with necessary deflection angles and minimal actuation force. This presents a multicriteria optimization with 6 objective values, 3 for upper deflection and 3 for lower deflection. The objective values were combined using weighting. The weighting coefficients a(i) where i = 1, 2, 3 have been chosen to give the final ratio of approximately 1:1:1 between the 3 objective value groups. This approach was selected because it was not intended to favorize or suppress the influence of any objective value in the objective function. However, the constraints for objective values have been added, which help to avoid impractical solutions with unnecessarily low failure index (FI). This was intended to reduce the impact of arbitrary weighting factors and created the sequence in satisfying the objectives as follows:
failure index – FIup, down;
deflection angle – δup, down; and
actuation force – qc up, down.
The objective function does not achieve a better result by further reduction of failure index values and deflection angles beyond the set threshold values. Therefore, it is possible to set the failure index value with a deflection angle, and any further reduction potential is then applied to reduce the actuation force. The deflection limits for the flaperon optimization can be selected as required by the application and the aerodynamic performance. The target deflection limits to be reached by the flaperon were selected −13° and +13°. This represents the lower portion of the regular control surface motion range, because the morphing uses higher relative airfoil chord ratio of moving surface. The optimization problem can be described by equation (1):
Deflection different from 13° is penalized in objective function by kup and kdown coefficients, defined in equation (2):
Objective function f is not reduced by reducing FIup,down under the threshold of 0.5 therefore in equation (3):
Failure index is evaluated by equation (4):
where σa = 200 MPa is allowable stress (same for tensile and compressive); σi is a von Mises stress on i-th element of the morphing skin, obtained from the structural solver solution across all load cases.
For this arrangement and equal weights of the objective values the weighting coefficients are:
Parameter vector x is contained in the space P with boundaries:
The minimum of ex is given by the upper curve inflection point, lower value would result in additional S-shapes in deflected state. The maximum of fx defines the rigid flaperon length of 5%, which was estimated as structural and practical minimum for trailing edge surfaces bond. The maximal ex and minimal fx are limited by each other, because those point shall not switch their positions. The selected values allow to vary the rigid flaperon length 5%–12% of the chord length and morphing skin length 1%−19.5% of the chord length. The combined length of the morphing skin and the rigid flaperon is 13–24,5%, which covers the usual chord ratio of control surfaces. The γ angle limits are equal to target deflection limits. The thickness parameter minimal value is the thickness of the single lamina layer, the maximal value was selected 1 mm for 10 layers. The actuation force qc is implemented as a distributed load [N/mm] in the spanwise direction. This allows to quickly identify the actuation force required per flaperon segment and choose the actuator parameters in the future. The bounds are given by orientation for up and down deflections and necessary range to reach the target deflections.
Problem is solved on a 10 mm wide wing segment corresponding to 10 elements in span-wise direction. The chord length is 500 mm. All loads are distributed loads and distributed moments. Aerodynamic force on the flaperon and the morphing skin was estimated using the CS23 AMC procedure for the wing loading 60 kg/m2, the pressure loading of 376,6 Pa was applied on both the morphing skin and the rigid body of the flaperon. The aerodynamic force orientation was against the flaperon deflection, therefore necessitating increase of the actuation force. Self-weight was not included, because it depends on the full internal structure of the rigid flaperon which is not yet available as the preliminary design focuses on the morphing skin. Moreover, in maneuvers the self-weight loads are significantly lower with opposite direction compared to aerodynamic loads, therefore lowering the loads carried by the structure. Morphing skin material was isotropic for simplification with Young modulus E = 6000 MPa, and Poisson ratio ν = 0.3. The elastic modulus resembles the equivalent elastic modulus of low modulus glass fiber reinforced polymer (GFRP). GFRP is suitable for its low modulus and has been successfully applied before e.g. by Smith and Lock (1992) and Vasista et al. (2019).
The optimization problem was solved using a genetic algorithm (GA). GA had been chosen for its robustness to expected multi-modality and ability to avoid local minima. Also, it did not require modifications to the objective function (which mainly follows the structural analysis workflow) to ensure it is differentiable. To solve the problem using gradient methods, it would be necessary to modify at least the stress function to make it continuous, unlike the search for maximum in equation (4). Gradient methods might be faster but may not reach the global minimum of objective functions with non-convex design space.
The MATLAB scripting with the build-in “ga” function has been used. The whole algorithm arrangement can be seen in Figure 3. Before the optimization loop, the airfoil is parametrized by the PARSEC method (Sobieczky, 1999), which is modified to properly represent the flapped laminar airfoil. The stress and strain sub-analysis were calculated using the NASTRAN solver. The single objective value evaluation includes three different FEM calculations. The upper deflection used the SOL 400 with geometric nonlinearity for strain and stress calculation, and therefore to evaluate the flaperon deflection. The lower deflection works similarly with opposite aerodynamic loading and actuation force orientation. Additionally, the SOL 105 for buckling factor was calculated for lower deflection.
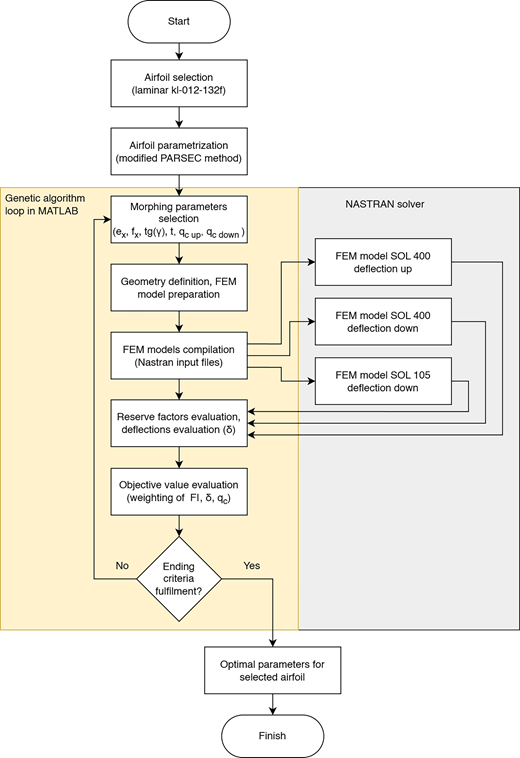
The GA u sed the stochastic uniform selection method – improved Roulette Wheel selection which uses single random value to sample all of the parents by selecting them at evenly spaced intervals. The recombination used the crossover scattered method, which is a type of single cross over. For mutation the Gaussian mutation method was used. The stopping criteria is a function tolerance of 1·10−4 and 5 stall generations.
Results
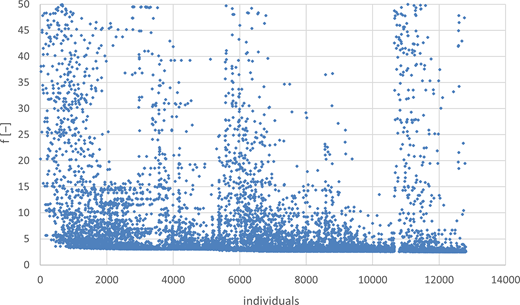
The result was obtained after the evaluation of 12,800 individuals (64 generations), where the objective value reached f = 2.5371. The evolution is in Figure 4, higher values are cropped.
The algorithm converges to a solution defining the location, length and thickness of the morphing skin and the rail angle. For each individual subcase solution, the distributed actuation force and respective deflection is available for both upper and lower deflection. The GA evolution of the parameters and the objective values can be seen in the composed Figure 5. The four geometric parameters are in the parts a) to d). The actuation forces work as both parameters and objective values, parts f) and g). Failure indexes of the morphing skin for the upper and lower deflections are parts h) and i). The achieved flaperon deflections are in part j). The calculated eigenvalues – buckling safety factor is in the e). The outliers of objective values were cropped.
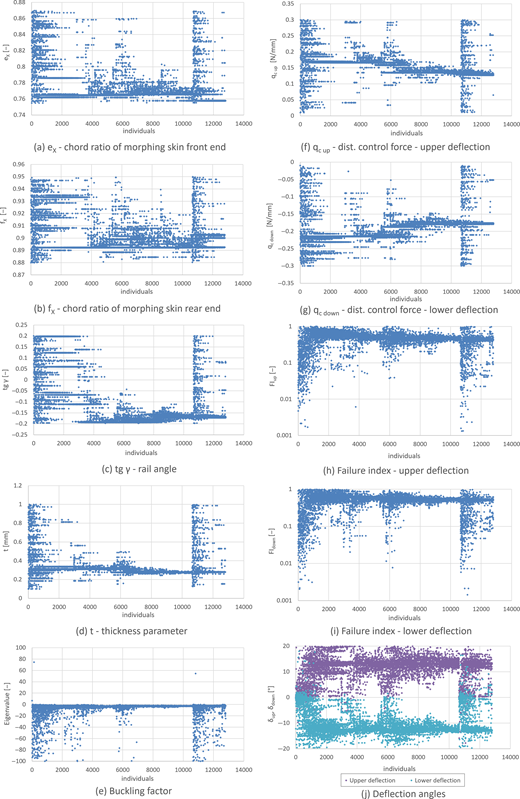
Parameters (ex, fx, t, tg γ, qc up, qc down) and objective values (qc up, qc down, FIup, FIdown, δup, δdown) evolution
Source: Authors’ own work
Parameters (ex, fx, t, tg γ, qc up, qc down) and objective values (qc up, qc down, FIup, FIdown, δup, δdown) evolution
Source: Authors’ own work
The output geometry achieved by the best individual of the last generation is:
The corresponding actuation forces are:
The failure indexes of the morphing skin for up and down deflections:
The respective deflections are 13.02 up and −12.78 down. The eigenvalue is negative: −2.21, the buckling does not occur under the current load orientation.
The upper skin curves of the morphing skin and the rigid flaperon at full deflections obtained for the parameters described above can be seen in Figure 6. The S-shape in the lower deflection, concave to convex curve change, can be considered undesirable, but it is a consequence of the rigid trailing edge part and morphing motion. Based on the optimized geometry the mutual relationship of the required actuation force and deflection angle was calculated for the expected range of flaperon motion in 1° increments. In this case, the aerodynamic force is assumed to act against the deflection of the flaperon because it is a reactive force. Therefore, to reproduce this behavior in simplified manner, each deflection step uses a fraction of aerodynamic force proportional to the deflection angle, where full magnitude is reached at full deflection of 13° positive and negative. This can be seen in Figure 7. The actuation force for flaperon deflection without aerodynamic forces was plotted for comparison.
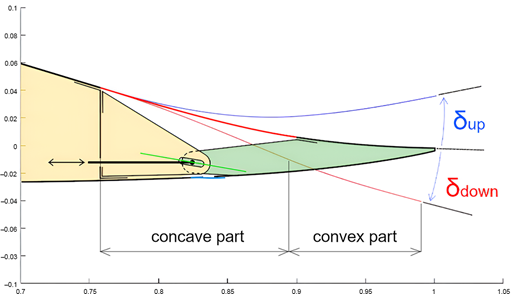
Optimized flaperon geometry with deflection curves achieved by morphing skin and rigid flaperon for up and down deflections, notice the change from concave to convex curve in down deflection
Source: Authors’ own work
Optimized flaperon geometry with deflection curves achieved by morphing skin and rigid flaperon for up and down deflections, notice the change from concave to convex curve in down deflection
Source: Authors’ own work
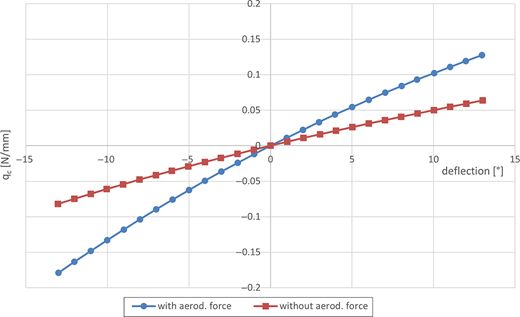
Actuation force required for deflection of flaperon, with and without aerodynamic force
Source: Authors’ own work
Actuation force required for deflection of flaperon, with and without aerodynamic force
Source: Authors’ own work
Discussion
The input parameters reached the narrow bands during the evolution as well as the objective values, the problem is well conditioned. The difference in the optimized up and down deflection is caused by the objective function and weighting. Figure 7 shows the actuation force gradient for upper and lower deflections. The actuation force gradient is higher for lower deflection and therefore the algorithm decides to leave the optimal deflection of −13° to decrease the actuation force. The morphing skin start and end locations show, that sole maximizing the morphing skin length was not attempted. The front end of the morphing skin at the lower boundary can be explained by the maximization of the force couple arm between the morphing skin and the hinge location. The rail angle is negative and close to the boundary. The morphing skin thickness is rather low, but not at the lower boundary. This can be caused by the negative influence of the thin skin on the tensile load capacity.
The ratio of the actuation force and aerodynamic loads is approx. 1:1, the ratio can be seen in Figure 7, where subtracting the aerodyn amic loads halves the required actuation force. This means the introduction of the presented morphing arrangement requires approx. 2 times the force of the traditional hinged surface with the control lever inside the airfoil contour. The increase is caused by the required deformation of the morphing skin. It points to the importance of actuation force reduction. But it must be remembered, that the aerodynamic load was obtained using a simplified AMC procedure and may vary with actual airfoil pressure field. Translation of the hinge in the rail at full deflection of 13° is approx. 0.8% of the airfoil chord length, which is rather few. This might require higher manufacturing precision than usual because the clearance at the hinge pin can lead to inaccuracies and the commanded deflection might not be reached. However, higher accuracy is generally more expensive and lowering the clearances can make the mechanism prone to jamming.
Non-morphing parts were considered rigid bodies, which cannot be achieved in practical mechanical engineering and must be addressed in later development. While the algorithm can be used with different airfoils, their behavior and resulting shapes will differ from the presented results and must be treated as such. While many dimensions were used in unit lengths, it must be reminded, that for structural solver, actual dimensions had to be selected. Actual chord length and skin thickness are the most distinct. Therefore, the generalization of the numeric results is limited and the presented workflow must always be applied to actual dimensions for selected cases of use.
Further work
Future research will focus on addressing the effects that were omitted in the preliminary design, like fatigue properties of the morphing skin, actual stiffness of non-morphing parts, rail forces and the distribution of the shear force. The demonstrator of the arrangement will be developed. The options to improve the built-in regarding different airfoils will be investigated. To accelerate the optimization, it will be necessary to improve the algorithm by structurization e.g. by iterative actuation force evaluation to save parameters. Unfavorable S-shaped morphing skin in lower deflection can be observed in Figure 6. This is caused by the initial airfoil shape in combination with morphing kinematics and needs attention in the later development phase.
Conclusion
The problem formulation as presented proved feasible and the GA is suitable for the solution. While the use of the threshold in constraints seems rather effective for the reduction of weighting coefficients selection, the effects can still be observed in final deflections. The actuation force required for morphing skin deformation remains relatively high. Further reduction requires morphing skin properties modification. The numerical results of the optimization depend on the selected non-parametrical properties and may vary significantly in future development phases. Despite the design originating from the sailplane technology development, the actuation force-related problems might limit the use of the presented morphing flaperon arrangement to small scale-aerial vehicles, where the aerodynamic forces are smaller and distributed actuation can be easier to include. Also, the better replaceability of smaller scale vehicles parts can help solving the fatigue related problems.
The presented approach can improve the systemic design of airfoil morphing with current materials and technology. This has the potential to improve several important aspects in aerospace development, including emission and noise reduction, due to gap elimination, full use of the material and the short-term application of the morphing.
This work has been supported by the project No. FSI-S-23–8163 funded by The Ministry of Education, Youth and Sport (MEYS, MŠMT in Czech) institutional support.

